Theorem 3.1.1 Jacobian of the Lagrangian-to-Eulerian map.
Since we assume the medium is continuous, we would generally require that the mapping from Lagrangian to Eulerian coordinates is continuous and one-to-one; then the map assigns every element (label) in the original reference configuration, denoted \(\bX\text{,}\) a unique position, \(\bx\text{,}\) in the deformed state.
From Multivariable Calculus, the map is locally invertible provided the Jacobian of the transformation,
\begin{equation*}
J = \pd{\bx}{\bX} = \pd{(x, y, z)}{(X, Y, Z)} =
\begin{vmatrix}
\pd{x}{X} & \pd{x}{Y} & \pd{x}{Z} \\
\pd{y}{X} & \pd{y}{Y} & \pd{y}{Z} \\
\pd{z}{X} & \pd{z}{Y} & \pd{z}{Z}
\end{vmatrix}
\end{equation*}
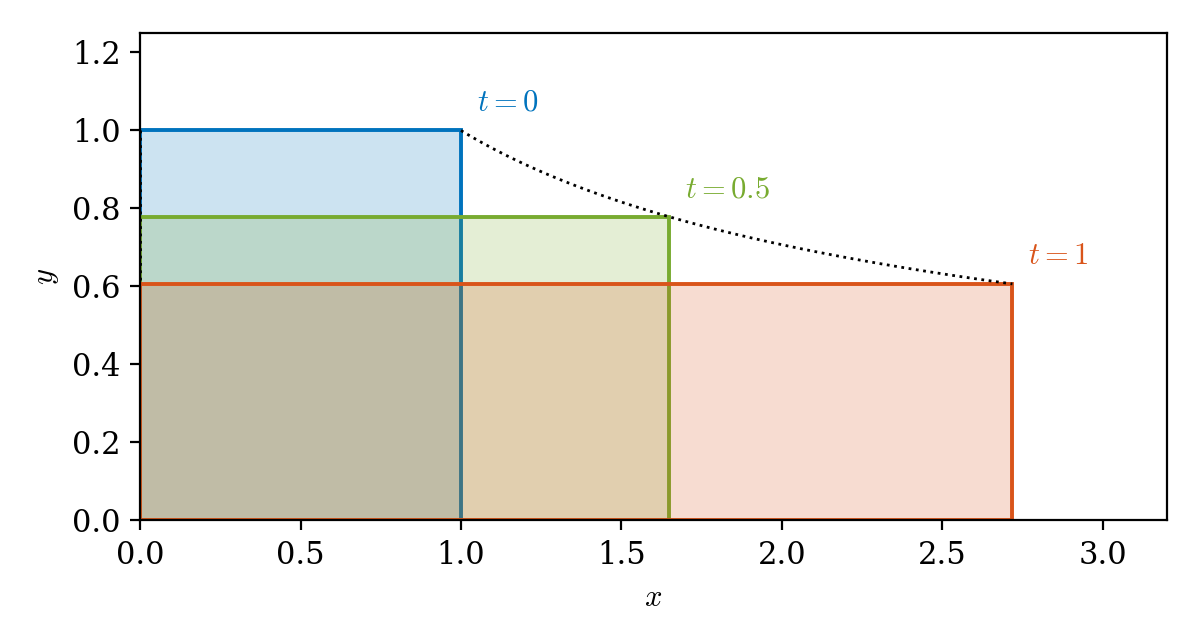
is finite and non-zero. Since \(J = 1\) at \(t = 0\) (when \(\bx = \bX\)) and \(J\) varies continuously in time, this means \(J > 0\text{,}\) i.e.
\begin{equation*}
0 \lt J \lt \infty.
\end{equation*}